Interactive Annotation (Desktop)
DIVE Desktop can run interactive point-click segmentation and interactive stereo tools backed by a local VIAME Python service. Both features are desktop-only and require a working VIAME installation.
| Feature | Description |
|---|---|
| Interactive segmentation | Click foreground/background points to generate polygon masks (SAM-style models when available). |
| Interactive stereo | Warp annotations between stereo camera views and recompute length measurements from head/tail lines. |
See also: Multicamera and Stereo Data, Annotation Quickstart, Keyboard shortcuts.
Requirements
- DIVE Desktop with a valid VIAME Install Path
- For stereo features: a stereo dataset imported with a calibration
.npzfile - GPU recommended for model load times; CPU fallback may be available depending on VIAME build
On first use, DIVE spawns a single persistent viame.core.interactive_service subprocess that loads segmentation and stereo models lazily.
Interactive Segmentation
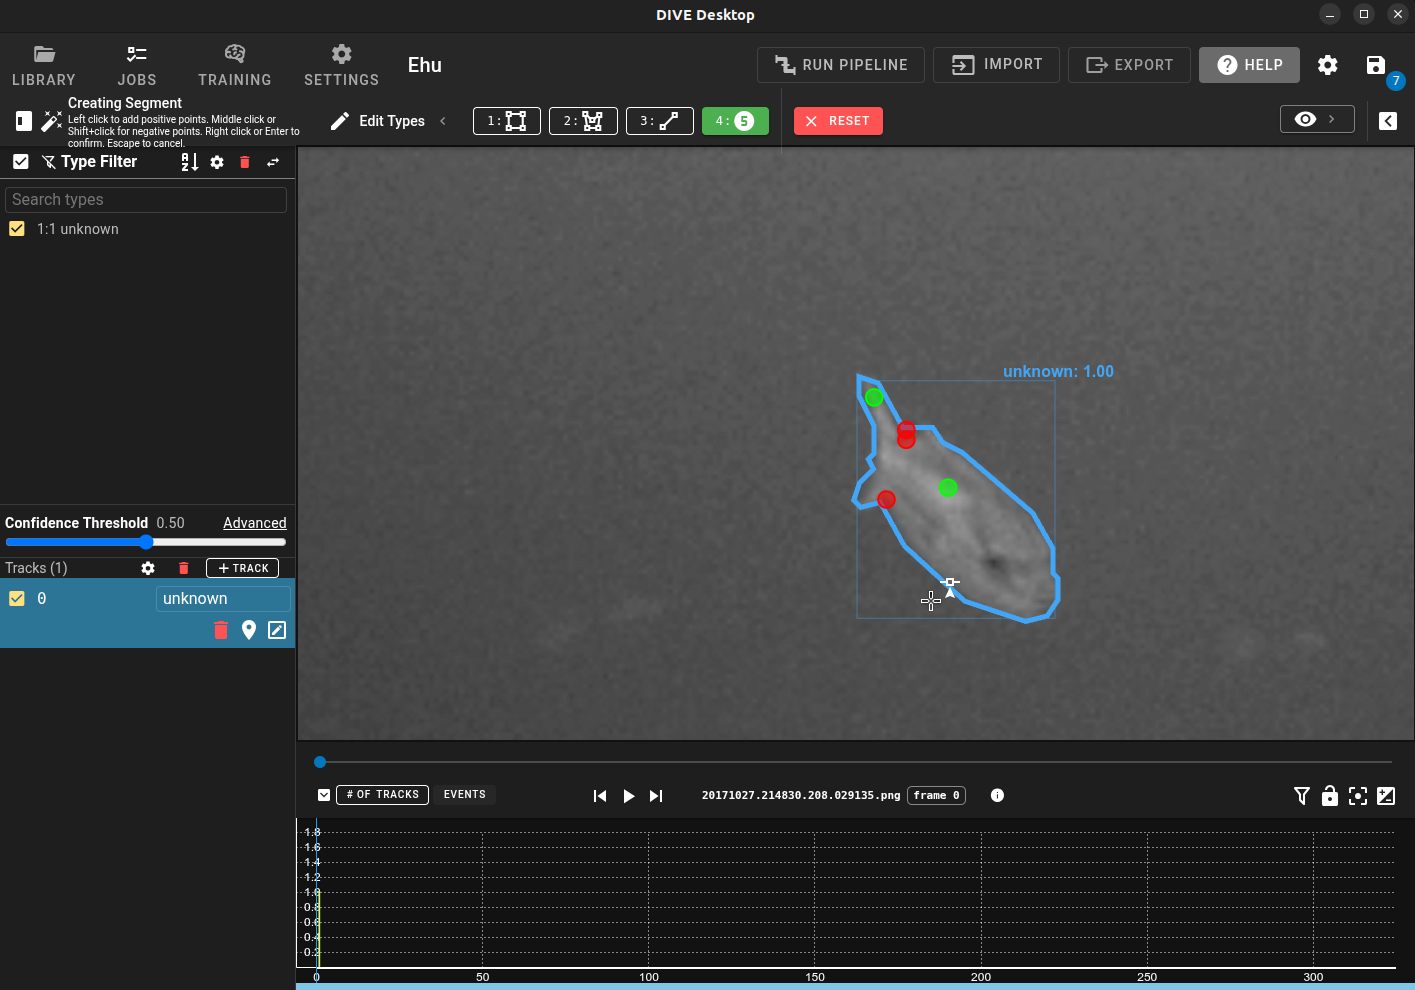
Point-click segmentation helps you draw precise polygon regions faster than placing vertices by hand. It is available on single-camera and multicamera datasets.
Activating segmentation
- Create or select a track/detection and enter edit mode (right-click the annotation).
- Click the Segment button (magic-wand icon) in the editing bar, or press S.
- On first activation, DIVE loads the segmentation model. A loading indicator appears in the status area.
The status indicator shows instructions while segmentation is active:
- Left click — add a foreground (include) point
- Shift+click or middle click — add a background (exclude) point
- Right click or Enter — confirm and commit the polygon
- Esc — cancel and clear points (restores the previous polygon if you were editing)
Green dots are foreground points; red dots are background points.
Resetting points
While in Point (segmentation) mode, click Reset Points in the editing bar to clear prompt points and revert to the pre-segmentation polygon without leaving segmentation mode.
Multi-frame and video
- Points are tracked per frame. Switching frames saves the current frame's points and shows only the active frame's prompt dots.
- Confirming commits all frames that have valid polygons.
- On video datasets, the service receives the frame timestamp so models can seek the correct frame.
Continuous detection mode
In Detection mode with Continuous enabled, each foreground click can start a new detection. Background clicks do not spawn new detections.
Stereo datasets
On stereo datasets, confirming a segmentation on one camera can warp the resulting polygon to the paired camera when interactive stereo auto-compute is enabled.
Note
If the primary segmentation model fails to load, DIVE may fall back to a GrabCut-based method with reduced accuracy. Check the desktop debug console (Ctrl+Shift+I) for details.
Interactive Stereo
Interactive stereo assists annotation on two-camera stereo datasets with a calibration file. It is controlled from the Stereo Settings section of the creation settings menu (gear icon in the track list or bottom panel).
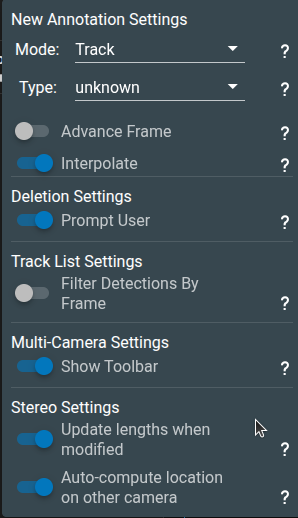
| Setting | Behavior |
|---|---|
| Update lengths when modified | When you edit a head/tail line on a detection linked across both cameras, DIVE recomputes stereo measurements (length, midpoint, range, RMS). |
| Auto-compute location on other camera | When you draw an annotation on one camera and the other camera has no detection yet, DIVE warps it to the other view using dense stereo disparity. |
Enabling either toggle loads the interactive stereo service. A loading dialog appears while models initialize.
Warped annotations
Stereo-warped head/tail lines become normal editable line annotations. If you manually edit a warped line, DIVE locks it from automatic re-warping so your corrections are preserved.
Auto-created head/tail connector lines use the standard head/tail line key and behave like manually drawn lines.
Multicamera workflow improvements
- One-click cross-camera edit — selecting a linked track on one camera selects it on all camera views and enables editing.
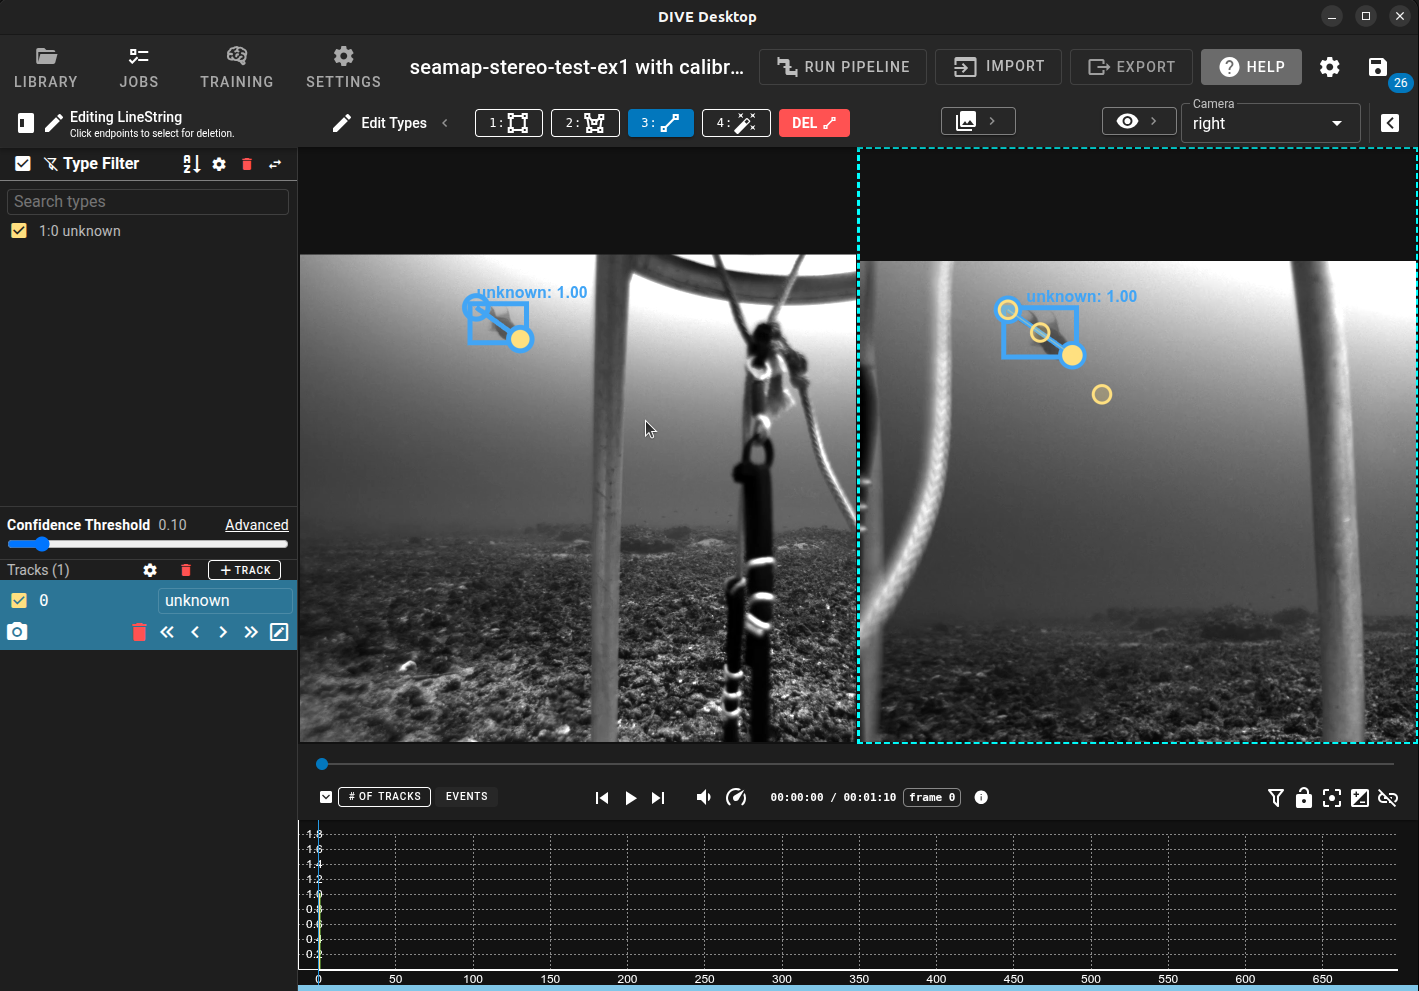
- Create on any camera — start a new linked detection from any camera view without breaking the multicam workflow.
- Line aspect ratio — auto-warped line bounding boxes are capped at a 6:1 aspect ratio for readability.
Measurements and export
Computed lengths are stored as detection attributes (for example length) and round-trip through VIAME CSV export. The legacy VIAME length column is also populated when a length value is present.
Troubleshooting
Unable to load the interactive service
Verify your VIAME Install Path in Desktop Settings. Ensure VIAME is installed with interactive segmentation/stereo support (see VIAME installation docs). Open the debug console (Ctrl+Shift+I) and look for stderr from the interactive subprocess.
Segmentation button missing or disabled
Interactive segmentation is only available in DIVE Desktop, not the web annotator.
Stereo settings not visible
Stereo settings appear only on stereo datasets (two cameras + calibration) in DIVE Desktop.
Stereo warp did not appear on the other camera
Confirm Auto-compute location on other camera is enabled, the track is linked across cameras, and the other camera has no existing detection at that frame. Human-edited lines are not overwritten.
Curved head/tail lines
Use the existing head/tail line tool: place the two endpoints as usual, then right-click the detection to edit its existing line. Click a new location on a line segment to insert an interior vertex, or drag its small midpoint handle. Drag vertices to adjust the centerline, or select an interior vertex and use the existing Delete point action to remove it. Removing the final interior vertex restores a two-point line. Deleting a vertex keeps the remaining line in edit mode. An existing detection box stays unchanged while all vertices are inside it; moving a vertex outside expands only the necessary box edges. No additional annotation mode is needed.
The displayed line is an open polyline, ordered head to tail. Intermediate points
are saved as spine_001, spine_002, etc.; insertion and deletion renumber them.
These names describe order within a detection, not anatomical landmarks or stereo
correspondences. Other keypoints and segmentation polygons remain separate.
With stereo length updates enabled, edits clear derived measurements and trigger
fresh correspondence along the curve. Failed matches leave the measurement stale
instead of keeping an old length. Explicit user_set lengths stay locked. Curved
measurement reports curved_length, straight_length, and curvature_ratio in
addition to the usual length field; this ratio is a bend indicator, not local
curvature. Computation follows the editable polyline, retaining its corners.
Desktop dense stereo transfers points and curved lines in either direction. Right-camera edits use a separately computed, cached right-reference disparity map. The web stereo matcher also supports edits from either camera.
With automatic mapping enabled, placing or moving a named keypoint maps it to the other camera, including when that camera already has a detection. Inserting an interior line vertex maps that vertex into the nearest segment of the other line, preserving its existing vertices. Automatically mapped points can follow subsequent edits; manually edited target points are protected. Failed matches and results that arrive after either affected annotation changes are discarded. These behaviors use the existing automatic mapping option in desktop and web. Browser ONNX matching supports transfers in either direction. Both implementations rematch image locations rather than pairing equally numbered intermediate points.